About Chanhui Kim

This author has not yet filled in any details.
So far Chanhui Kim has created 5 blog entries.

Spartan (971) Week 0 Scrimmage

By |2026-09-20T15:36:43-07:00March 10th, 2026|

Arriving at the 971 Week 0 Scrimmage event site, we safely offloaded the pitcases and robot from the trailer, and unpacked our pit cases in our designated pit location near the field. The team worked well getting everything set up, including configuring our RADIO so we could move to field calibration. We also had a few of our team members help out by volunteering at the event, covering field resets, refereeing, and clean-up at the conclusion of the event. The Spartan Week 0 event was incredibly successful for the team, resulting in many learnings from working in the pits with new students, how the robot operated on the field in an Alliance with 5 other robots on the field, and potential match strategies. The team used these learnings to inform what to focus on as we prepare the robot and spares for the  Week 2 Silicon Valley District event.  The robot performed well and exceeded our expectations for a week 0 scrimmage. From a mechanical design standpoint, the robot was thoroughly battle-tested during matches. It absorbed several hard impacts with both field elements and other robots, demonstrating that the team has built an incredibly reliable and robust robot. Members of the drive team gained valuable experience working behind the glass with other team members during the match. We significantly [...]
Build Season Week 7 Blog

By |2026-09-20T15:39:00-07:00March 3rd, 2026|

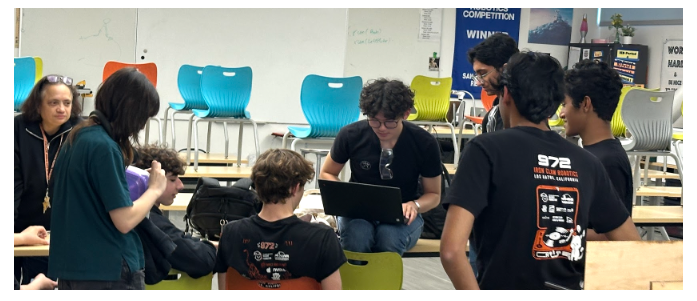
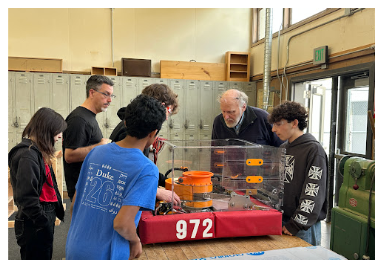
Week 0 Scrimmage Preparations: As we continued to work towards the Spartan Week 0 event, we finalized the list of our competition members in both the pit team and strategy. We made some final touches and adjustments to have a competitive robot to field at the event. The week leading up to the event, we allowed the software team to make some major improvements to the robots functions while our new driver and drive coach got prepared.Intake / Store Testing: Throughout the preparations for week zero we made minor tweaks to the intake and store subsystem, our testing revealed some performance issues which need to be fixed. We found that many of the balls would shoot out of the top of the hopper rather than going into the dye rotor (spindexer), so we added a net to the extending portion of the hopper. Shooter Testing: Over the past two weeks of FRC, our team has had several successes and roadblocks. Our turret now aims exceptionally well using a phase shift combined with the robot velocity. It’s been smoothed with a linear filter for limiting jitter. Our shooter and hood are currently operating well, and have a strong outtake speed, looking forward to seeing how it works at the Week 0 Scrimmage. Some future improvements is tuning the shooting so it works [...]

Build Season Week 5/6 Blog

By |2026-09-20T14:41:03-07:00February 24th, 2026|

Convergence: Build Week 5 & 6 which span work days 21 to 30 for our team is the time of convergence. Drivetrain and Control System Board (CSB) were completed by Work Day 12. The software groups worked on code to validate what would be required for each of their respective sub systems, the various CAD groups turned prototypes into real subsystems, going through many preliminary design reviews (PDRs), iterations, and then final critical design reviews (CDRs). The Spindexer (dye-rotor), floor and racetrack required some extra time to finalize their designs. During this time the manufacturing group started to manufacture subsystems that cleared their CDR phase, our 3D printers have been working overtime as well. Subsystems assembly teams have been very busy. Our three robot driver candidates continued to practice with our prior season robots to get familiar with optimal drive paths within the Alliance and Neutral zones, traversing the bump and going under the trench. Intake and Store: Assembly work was completed on the intake and store. The Control Systems team completed all the wiring. We moved the robot to the field to validate the end to end operation by turning several tests. Our robot driver was able to test acquisition of game pieces running at various speeds while the intake and store hardware and software team validated everything [...]

Build Season Week 3 Blog

By |2026-09-20T12:45:49-07:00February 3rd, 2026|

At the start of build week three, our Decision Voting Committee (DVC) made some important decisions regarding what mechanism had conceptually demonstrated the ability from a hardware and software point of view to support our functional requirements & strategy, and what mechanism would be given an additional week of prototyping time. Our Intake and Store, Spindexer, and Turreted Shooter were approved for our competition robot. Our two climb prototypes were given another week to finalize their prototypes. Intake & Store: Over the past week, our team has been completing the intake CAD. We decided to do a linear intake with an extendable hopper on top of it, so it can store more balls. For this design, we made the hopper extend horizontally while the intaking mechanism extends at an angle, allowing us to have a higher capacity while still fitting under the trench, even when the intake is stowed. We are now finalizing our mounting system, which will allow our manufacturing team to get to work. Spindexer: With the decision to move forward with the spindexer our cadders started working on the CAD for a more complete design based off of our prototype to be integrated with other subsystems. We are taking inspiration from the 111 Wildstang’s spindexer blog as well as 125 Neutron’s 2017 bot. We are now finalizing [...]

By |2026-09-20T00:39:33-07:00April 1st, 2025|

Returning from the SAC regional, the team made notes to get ready for the next competition, the East Bay Regional (EBR).  The team met up for a competition debrief in the beginning, which includes discussion on the scouting app and the robot improvement. We realized that driver practice and auto-routine would be the main focus of week 4 and 5. Another meeting on Friday, the team began fixing a few minor flaws in each subsystem. As from the competition debrief, we decided to use aluminum as the material for outtake. Along with the outtake, the team had agreed upon more molded wheels on the intake. Observing from  the SAC regional, the team realized that more wheels on the intake can help us obtain a “touch it and own it” intake system. Not only the improvement made in the intake subsystem, the team also fixed the elevator to make it more sturdy and stable when it is reaching from L1 to L4. The software and the hardware systems fixed the elevator along with the end effector to allow us scoring from L1 to L4 without any issues. Vision is also improved to fully-autom ated scoring. Apart from our subsystems, we fixed minor electrical problems we had before during the SAC Regional, for example, the CANcoder and the Kraken motors that [...]

Go to Top