About Roxanna Abdollahi

This author has not yet filled in any details.
So far Roxanna Abdollahi has created 10 blog entries.

By |2026-09-19T22:57:21-07:00April 16th, 2025|

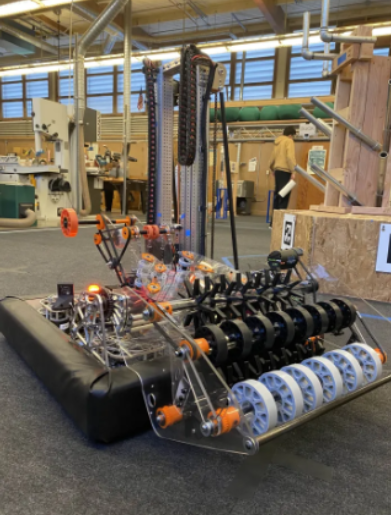
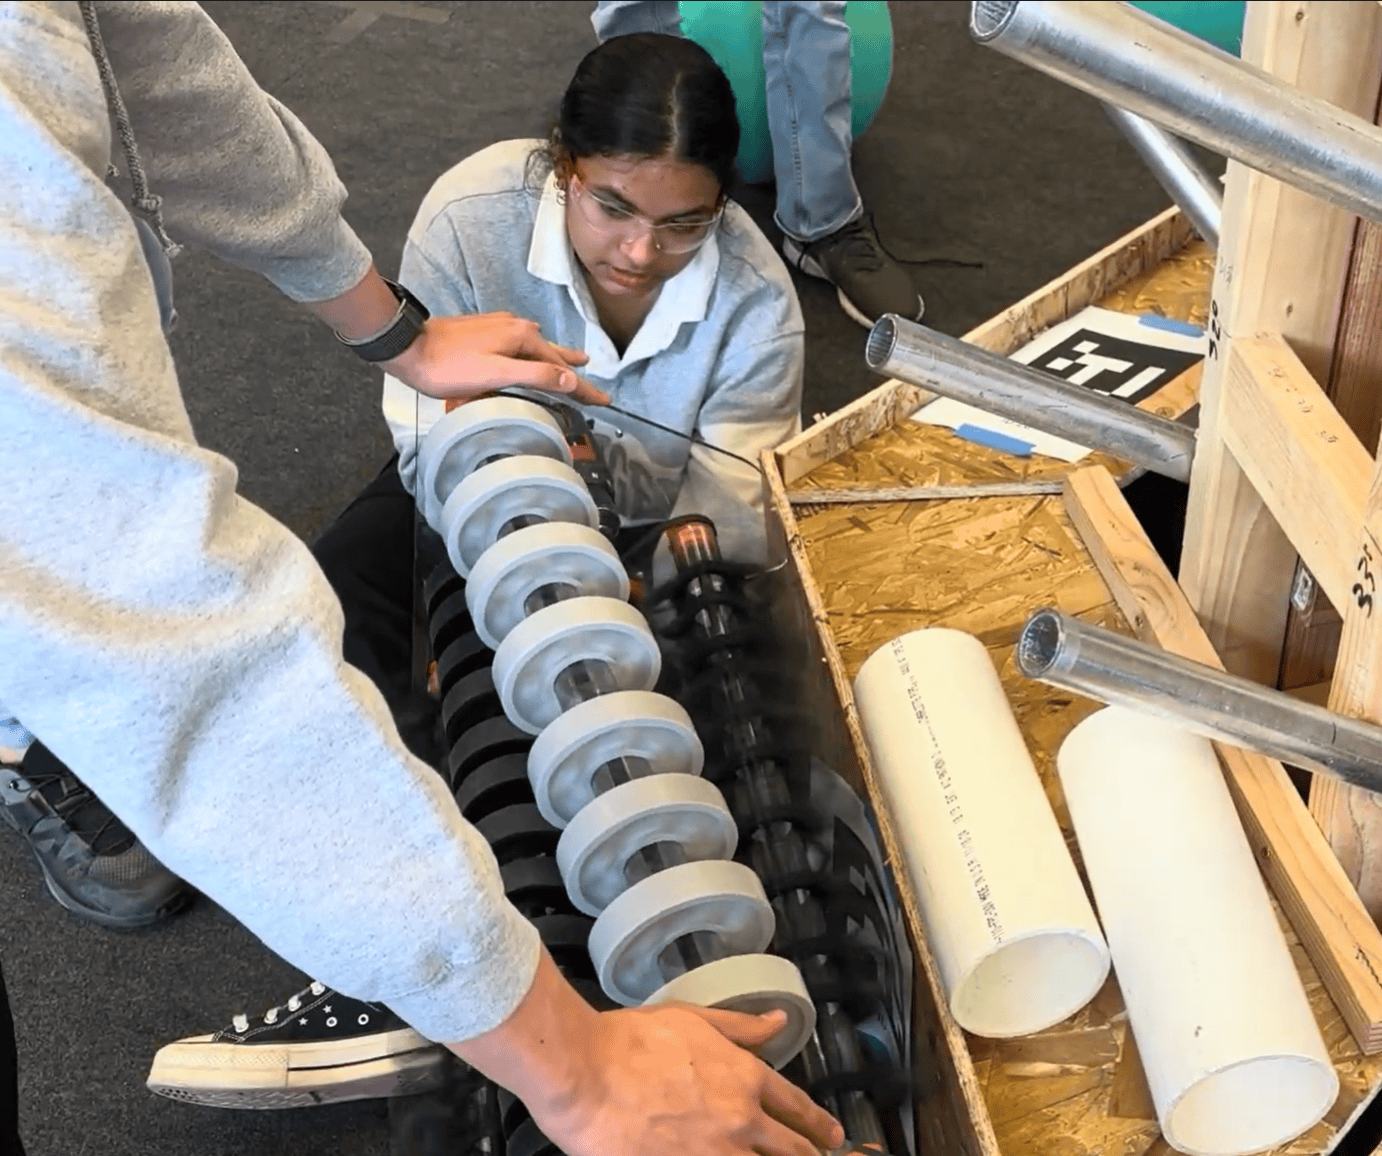
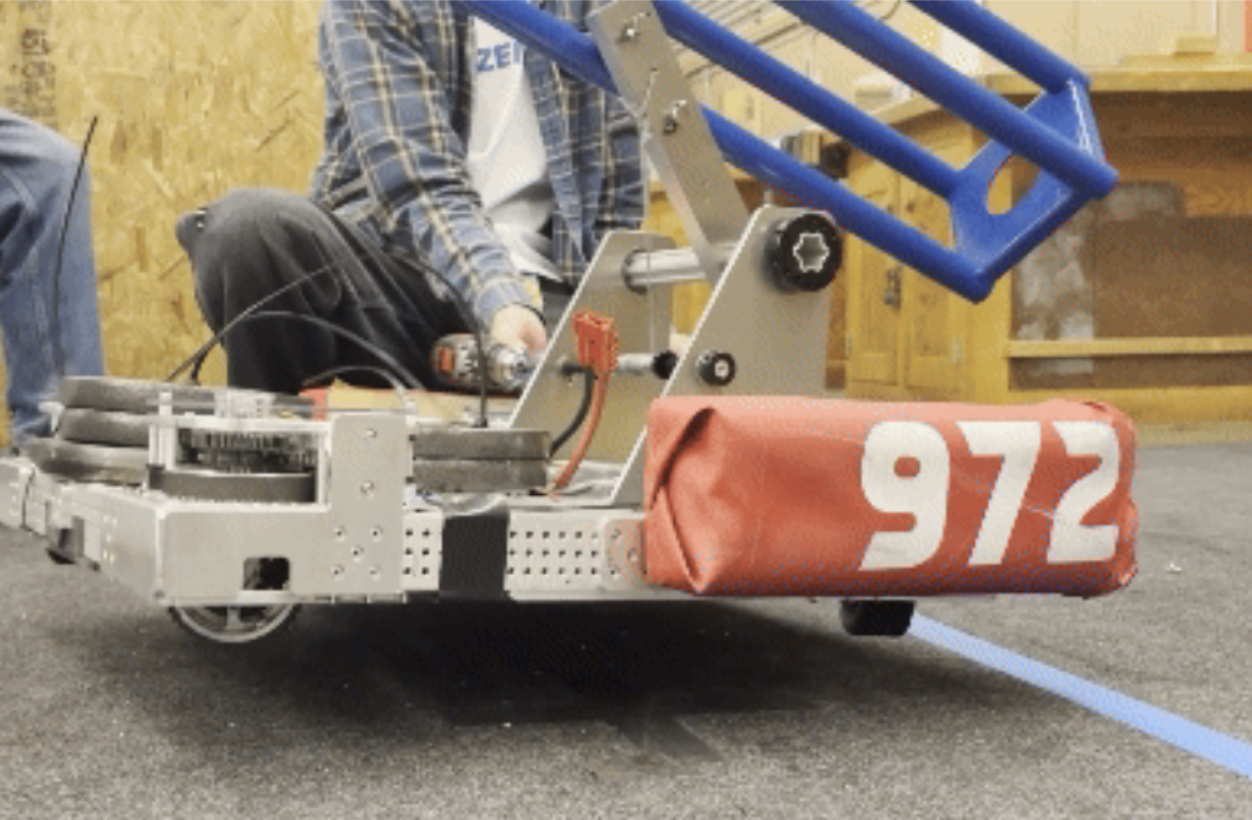
This week, we made huge improvements to be well prepared for the East Bay Regional (EBR). Since we finished CADing last week, we were able to start assembly immediately. This week has been packed with testing, improvements, and strategic discussions as we gear up for upcoming competitions. From refining intake mechanisms to optimizing our scouting app, every detail is being fine-tuned to ensure peak performance. We assembled spare components onto the beta bot for testing purposes, ensuring reliability and durability under competitive conditions. Additionally, minor improvements were made to the scouting app to allow for better usability and efficiency. To address control system stability issues, adjustments were made to the plate under the CANivore. On Wednesday, we focused on improving the practice field to better simulate real competition environments. By Friday, we had fixed the camera mount to ensure better visibility and alignment during matches. A new intake system with a larger wheel was implemented to address the issue of pushing the coral away during both practices and competitions. We are currently testing different wheel sizes, comparing 5-inch and 3-inch wheels, while evaluating the impact of material flexibility under high-speed rotation. Significant progress was made on Saturday, with improvements to the elevator rope mechanisms for better stability and control. The energy chain routing was also covered in stripes to [...]
By |2025-03-19T17:30:02-07:00March 19th, 2025|

On Monday, the team made significant progress in assembling key parts of the robot. With our new designs coming together, we focused on refining vision alignment by retesting the angle and direction of the camera for auto on the old robot, ensuring it properly detected AprilTags for more precise movement. Meanwhile, our driver continued practicing, further improving his skills to maximize our robot’s performance on the field. The control systems team worked on crimping the e-chain. Additionally, we finished assembling our third elevator of the season. We also had many students in the classroom building spare subsystems for Vantage and disassembling subsystems from the older iteration for spare parts. They labeled them and packed them into our pit and trailer. At the end of the day, we finished wiring and tested the new coral and algae scoring mechanism on our field, running a few cycles to check for reliability. We also worked on organizing the pit, making sure everything had a designated spot to make setup easier at competition. We checked our packing list multiple times to ensure we had all necessary tools and backup parts. Once everything was prepared, we loaded up our trailer and sent it off to the competition. We also posted our robot teaser, which was exciting to finally share after all the work that [...]

By |2025-03-19T16:09:06-07:00March 10th, 2025|

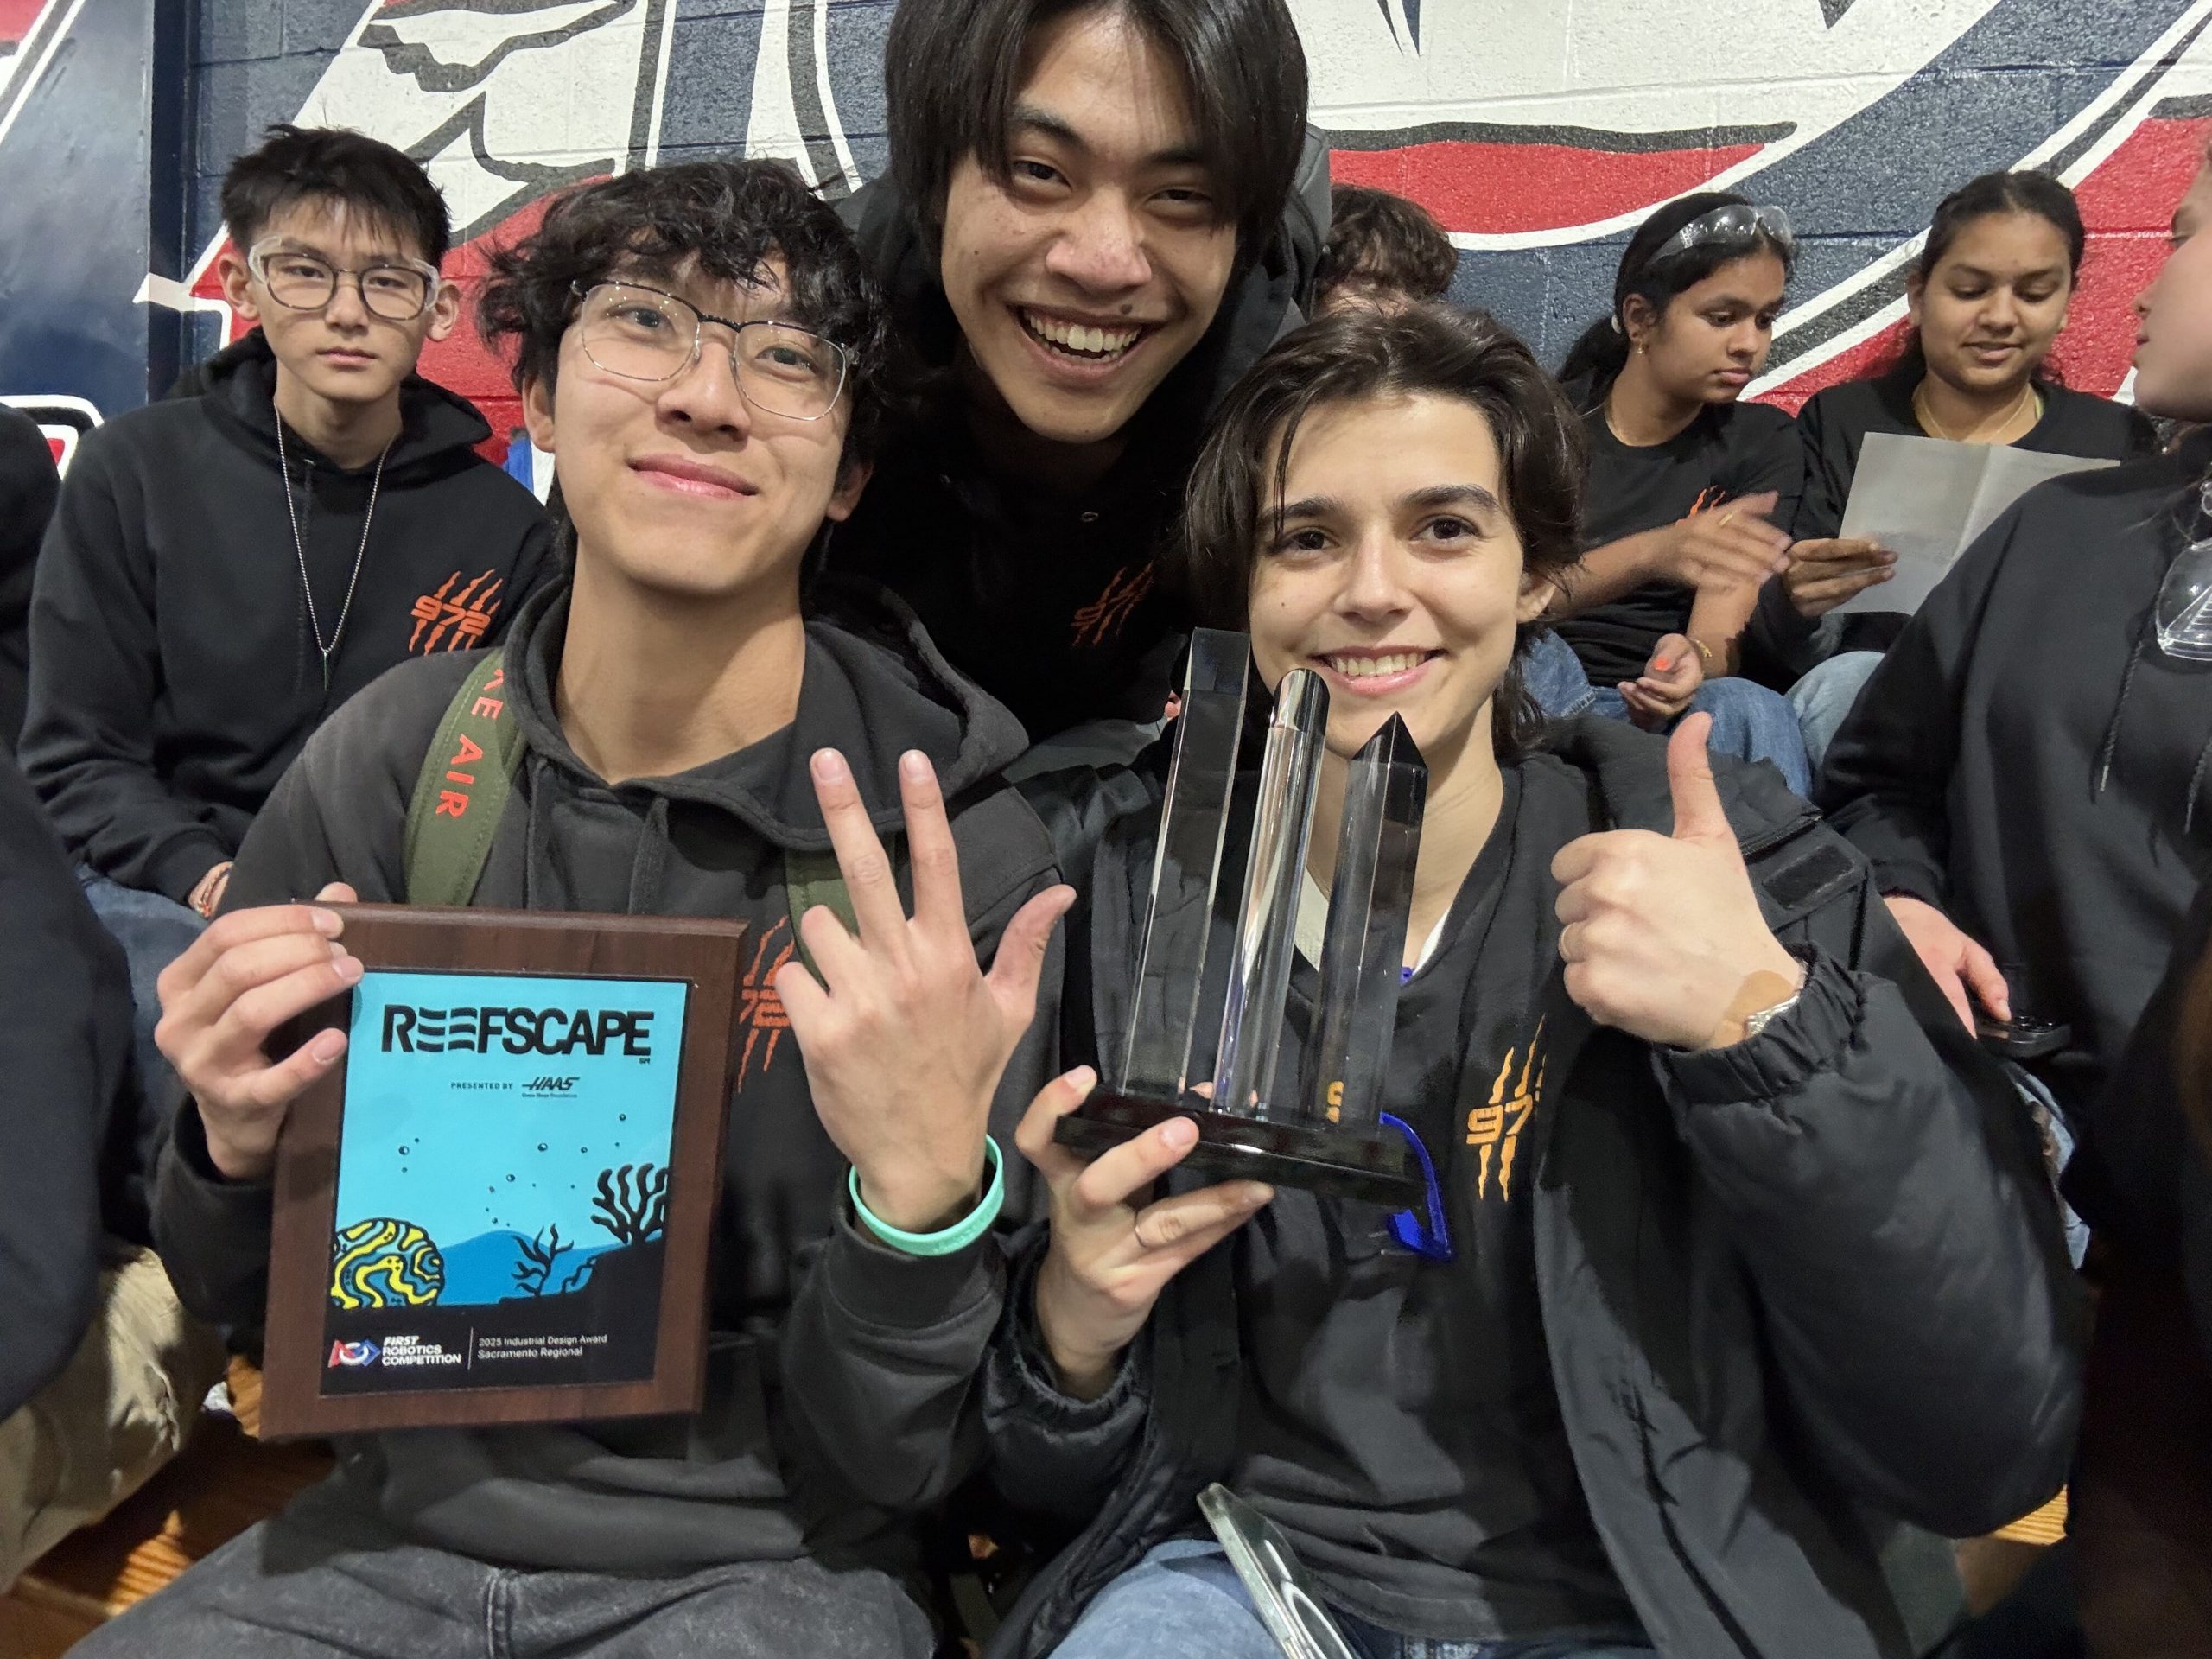
Leading up to the event, our team was in full-on work mode, focusing on three key areas: refining our autonomous routines, perfecting our coral scoring, and ensuring our climb was rock-solid. Our programming team worked tirelessly to get our auto consistently hitting Level 4 during practice, while the mechanical and design teams collaborated with the drive team to fine-tune our climb along with the different communicative elements of our PS5 controller. Friday was all about practice matches. Our auto performed somewhat consistently, hitting Level 4 and giving us a strong head start in every game. Even though our vision system wasn’t fully operational, our driver delivered an outstanding performance on the field. And our climb is currently 8th in the world. Thanks James! (Our human player was the main designer behind it). It worked flawlessly every match, securing crucial endgame points. Seeing all our hard work pay off was an incredible feeling. Saturday: Quals and Quick Fixes Saturday’s qualification matches brought intense competition. We noticed an issue with our coral intake and outtake system—corals would sometimes slip or drop during the switch from auto to teleop. We also noticed that the angle on outtake wasn’t working well for L4, messing with our auto and teleop cycles. Fortunately, our new scouting app and video reviews helped us quickly identify the [...]

By |2025-02-21T10:41:28-08:00February 21st, 2025|

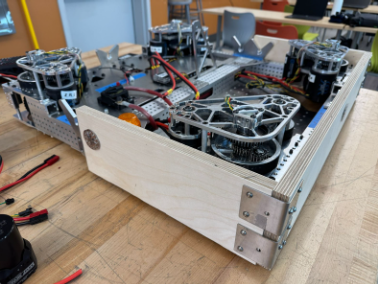
             We started the week by assembling the final subsystems of our robot. We mounted and calibrated the elevator, worked on bumpers, began manufacturing parts for our intake and indexer, and mounted the outtake onto the elevator. Meanwhile, our Software team created code for each subsystem to streamline the final weeks of integration testing before our week 1 competition.              On Wednesday, we began assembling the deep cage climb mechanism. Our manufacturing team quickly made the necessary parts, allowing the assembly to proceed smoothly. Our Software team also continued refining our intake and indexer code, and our Control Systems team attached the energy chain to our elevator.              On Saturday, our hardware team calculated that our robot would be overweight. They immediately brainstormed creative ways to reduce the weight. They decided to switch the Drivetrain rails from 1/8 to 1/16 inch, the Battery belly pan from 1/4 to 1/8 inch with an additional weight reduction grid pattern; the polycarb cover for the control system board was also reduced from 1/8 to 1/16 inch. Manufacturing for these changes began immediately. The upside is the team would now have a beta bot that will be used to test and finetune near-final subsystems, and auto routines, and allow our driver to continue to practice on our practice field while [...]

By |2025-02-19T15:33:17-08:00February 11th, 2025|

             With our first competition just around the corner, every second counts. We pushed forward on all fronts during week 5—manufacturing, mechanism assembly, coding, scouting, and more—all while making exciting progress on our robot and beyond.              On Wednesday, we held a critical design review. We discussed minor changes to our mechanism designs to reduce size for better packaging, improve coral lifecycle from intake to outtake, and keep our robot weight below 115 lbs.              Our scouting app team has also made significant progress. They implemented data visualization in the form of charts, which made the analysis process quicker. Additionally, we finished assembling the elevator and tested its voltage to check its efficiency.              Our vision team continued to perfect their integrated vision assist when approaching the reef to score. With the new bumper rule changes, the team has decided to use EVA Foam over traditional solid-core pool noodles. The EVA foam has proved easier to work with, as we were able to order 40 x 80 sheets and cut them down to the required size for baltic birch bumper backings. This year, we are making practice bumpers in addition to our comp bumpers.           [...]

By |2025-02-06T20:16:34-08:00February 6th, 2025|

             Over the course of this week, our team has made steady progress toward finalizing our Reefscape competition robot! Our driver, Arman, continues to practice with the Crescendo competition robot, Alphabot, and the Reefscape competition drive train. Arman has been testing out different controllers, he recently settled on the Scuf Reflex FPS controller.              Eric and Max had another productive week working on the scouting app. The UI was finalized, AI features were added, and it is now able to record scoring for Auto, Teleop, and Endgame!              While we are mostly done with the prototyping phase of our build season, our CAD team is working hard to finalize the competition robot CAD and drawing files for handoff to the manufacturing and assembly teams. The Reefscape robot's weight limit of 115 lbs, is proving to be a bit of a challenge, so our design team is looking for creative ways to reduce the weight of our robot and to improve the packaging of the subsystems onto the swerve drivetrain.              As mentioned in last week’s blog post, we decided on a 4-degree angled elevator mounting to simplify the end effector design. The manufacturing team has completed manufacturing all the [...]

By |2025-02-03T10:16:35-08:00January 29th, 2025|

             Following a restful MLK long weekend, we continued with data testing, creating many new prototypes, and making some important decisions. On Tuesday, our Design Voting Council (DVC) voted on different orientations of the elevator. They settled on an elevator oriented on its side, angled at 4 degrees, due to its benefit of taking up less space. We also started planning which awards we are going to pursue, working on our tech binder, and ordering apparel. We ended the day with our weekly stand-up presentation.              Throughout the rest of the week, we continued prototyping various mechanisms for deep climb, coral intake, and our autonomous routine. During this time, we decided to test an offset bicep climb to see if it would be possible to place the mechanism on the side of our robot. Through many trials, we observed that the bicep arm with an offset often slipped off the cage.              In parallel with the deep cage climb and autonomous path testing, our team has started testing intake from every orientation. Depositing the coral into the trough (L1) has met our functional requirement of 95% or greater for scoring L1. We also tested stacking coral in the trough to maximize our earned points. [...]

By |2025-02-02T14:49:09-08:00January 24th, 2025|

             This past week has been extremely productive for our team, with significant progress across various areas. On the prototyping side,  we continued working on the intake, outtake, and our deep cage climb.              We have been avidly testing ways to pick up coral from every orientation on the ground and trying various indexers to re-orient the coral into a vertical position so our robot can score it in the trough (L1).              Over the weekend, we assembled and tested our bicep climb mechanism. We made solid improvements to the lever tube, switching to 4 ¼” plates for version 2, enhancing its strength. We added some extra weights to imitate a robot's realistic weight. We’re also looking into ways to enhance alignment and efficiency, including pocketing and experimenting with alternative lever materials. We also developed a second version of the outtake to enhance its functionality. We’ve completed the drivetrain assembly and the control systems board. Additionally, we installed the climbing cages on the practice field, where we had the opportunity to host Team 971 on Thursday who were doing some auto-testing on their dev robot. We also continued testing on our Alphabot, practicing cycle times and how quickly our robot can score coral on [...]

By |2025-02-02T14:50:59-08:00January 11th, 2025|

             After exciting anticipation for the game reveal over winter break, we gathered to watch FIRST’s live stream. We then went straight to reviewing the game manual and brainstorming robot strategies. Our first few days of the season were spent honing in on our robot’s functional requirements and strategy. We also met with the FRC teams BREAD, GravitechX, and NerdHerd to get an outside perspective and exchange ideas.              After deciding our initial strategy, we researched design ideas, taking inspiration from past games and open alliance teams. Before committing to any specific robot design, the team split into Design Groups, each tasked with exploring separately to avoid the entire team fixating on just one design. These teams focused on analyzing scoring potential, identifying challenges, and understanding the game's nuances to optimize gameplay efficiency. Then, we reconvened to collaborate and discuss overarching designs to decide what we would need to prototype. We decided to prototype a ground intake that picks up coral from all orientations and a climbing mechanism inspired by Rust Hounds from Ri3d.              In conjunction with the prototyping groups, a separate group focused on designing the first iteration of our Alphabot. The Alphabot combines our off-season project, a two-stage cascading elevator, a [...]

By |2025-02-12T16:01:44-08:00November 20th, 2024|

             The new year means setting up for success, including organizing our Pit, managing operations, and handling new material shipments. Our shop manager, Ellery Han, has been cleaning the Pit and delegating tasks to sort last year's parts, screws, and miscellaneous items. A well-organized Pit is crucial for efficiency. With packages arriving nonstop, we order early to avoid delays and ensure we have everything needed for the Fall and Build Seasons. Students help sort and take inventory, ensuring each subteam knows what materials are available for their projects.              The operations subteam, in which all members are required to contribute at least 4 hours of admin tasks and additional upkeep work, is led by our new operations director, Claire Mayder. She’s been training new students and leads, applying for grants, and more. Our new communications lead, Jahnvi Bheemarasetti, assists Claire.              Our team fundraises the majority of its money in the Fall Season, this includes receiving money from sponsors such as the Wild Cat Foundation–our school foundation that raises money for school-related activities. Big thanks to them as well as all of our other sponsors! We’ve also had significant work done in documentation for operations to ensure efficiency in the build season and [...]

Go to Top