By |2022-01-23T22:49:02-08:00January 27th, 2020|

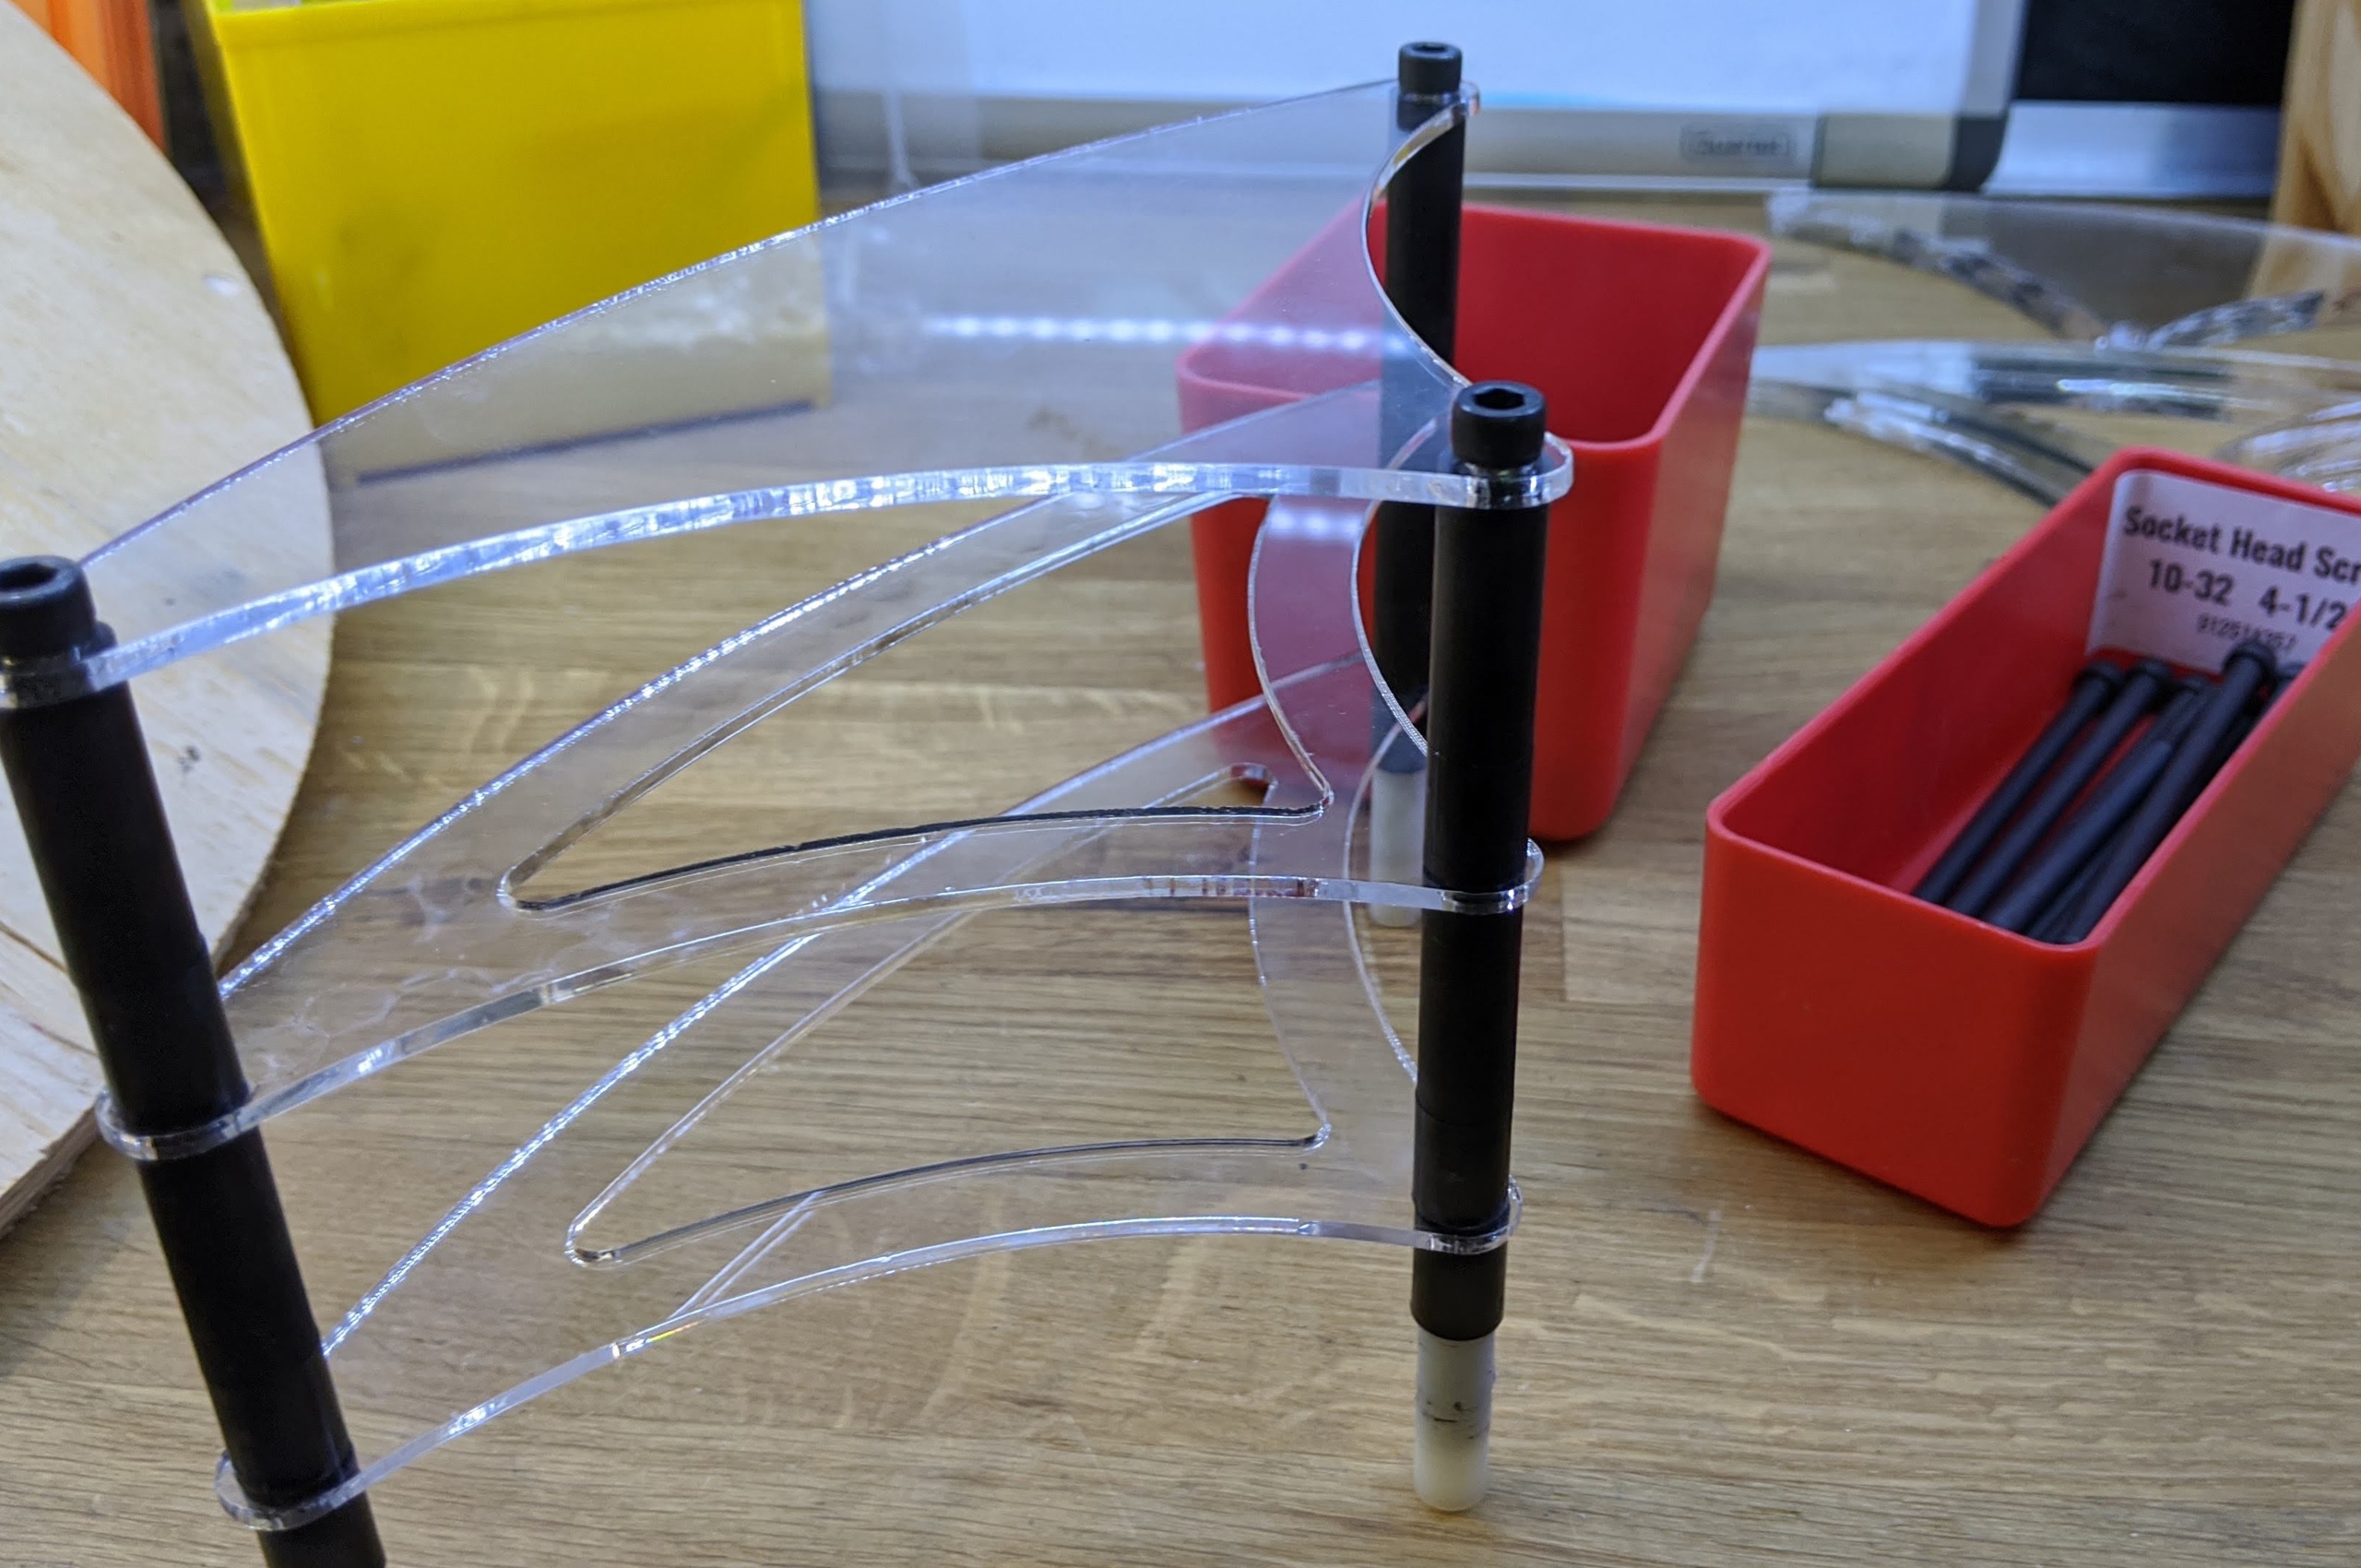
Week three was centered around prototyping, much like week two. To begin, we had two main indexing prototypes. One was shaped like a C, dubbed the reverse scorpion. Balls travel along a belt before being brought to a shooter. In the photo, our single flywheel shooter is pictured.  The second indexing design was a rotating magazine of game pieces. Students were inspired by videos from other teams, one of which this prototype was directly inspired by. A rotating base brings balls to a spinning wheel in order to get the balls to eject into the shooter.  By the end of the week, our DVC (Design Voting Council) decided on furthering the rotating indexing mechanism rather than the C indexer. The reasoning behind this was the issue with height. Since we had already decided on a shorter robot, the C indexer posed a disadvantage in regards to height, even though both designs were comparable in their vertical footprints. Students thought that the rotating indexer could be more easily shortened, while shortening the C indexer would affect the compression of the balls. The C indexer prototype was also shown to struggle with manipulating five balls, while the rotating indexer did not have the same issue.  The laser cutter is still at work! Since we are in [...]
By |2022-01-23T22:48:56-08:00January 20th, 2020|

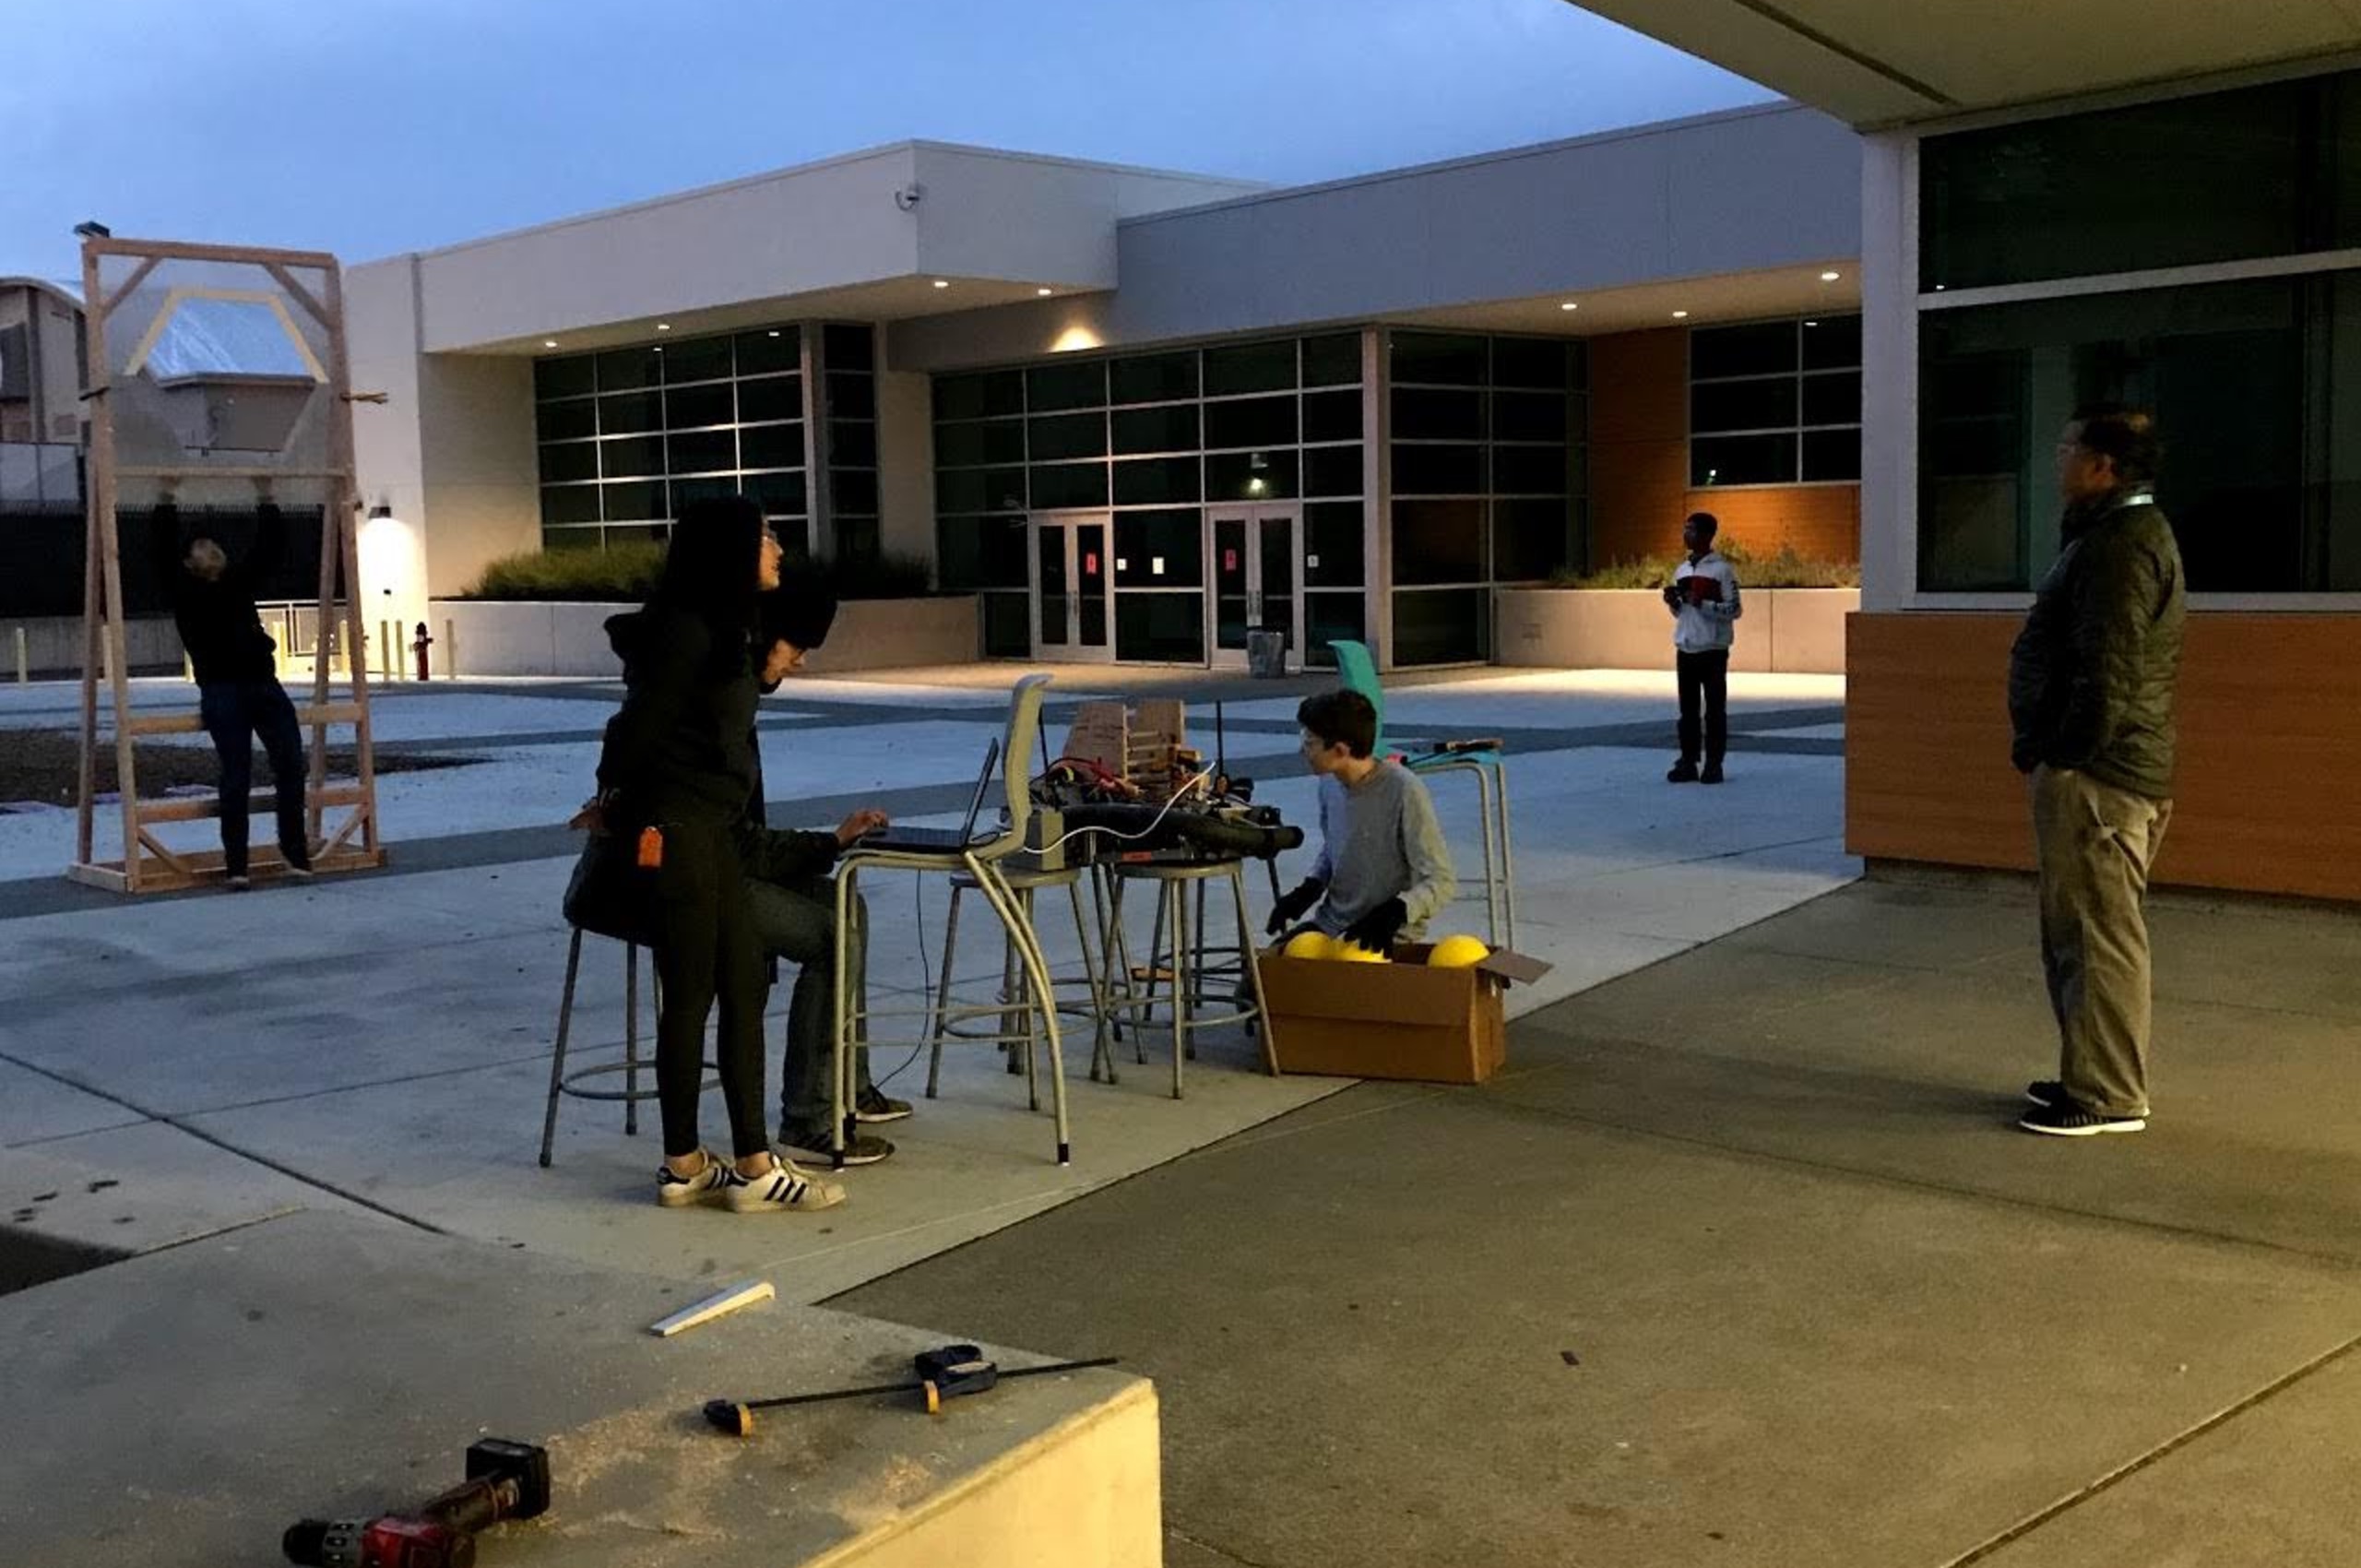
This week, we continued with prototyping by splitting into three main groups: indexing, shooter, and intake. For indexing, or ball manipulation inside the robot, we decided to CAD and prototype the c-index as well as a spiraling prototype. Furthermore, the shooter group prototyped a single-flywheel shooter, and they are making great progress on improving the precision and accuracy of it. They have started calculating the optimal angle and velocity at which to shoot the ball in regards to the outer port. The shooter group will also be prototyping a double flywheel shooter to see how it compares to the single flywheel. The intake group was also hard at work exploring different variations of a rolly grabber. Although we haven’t finished all the prototypes and finalized our design, we made some excellent progress this week and we hope to decide on a design next week. In addition, we finished assembling the chassis of our robot, the foundation for all of our mechanisms. We decided on a smaller size robot this year, being 26”by 30”, compared to last years’ 30” by 30” chassis. We believe that this smaller design will be beneficial during matches due to the fact that we can fit under the Control Panel. We decided to make a shorter, smaller robot because we [...]

Go to Top