About Iron Claw Editor

This account is managed by the Iron Claw Robotics website team. Blog posts published by this user are either written by students outside the website team or written by multiple people.

By |2023-03-29T14:57:36-07:00March 27th, 2023|

Coming back from the San Francisco Regional, our team was motivated and inspired. This past week, our team focused on not only improvements for our next competition, the Silicon Valley Regional, but for the Houston Championships as well. Some of our goals for the upcoming competitions are to create more high-scoring autonomous routines, implement the vision system, and to fix some mechanical issues. During the San Francisco Regional, our team witnessed the full potential of what a strong autonomous routine can be. Our winning alliance partner, 971, had an incredible autonomous routine consisting of scoring three game pieces. This consistently brought our alliance into a strong position before the teleoperated section. While we were unable to execute such an ambitious auto routine, we are optimistic about the prospects of what our programming team can accomplish.  This year’s vision system includes the addition of the April Tags. April Tags are squares with unique patterns that are placed at significant positions on the field. We were hoping to have vision fully functional by the San Francisco Regional, but after realizing the limited amount of testing that our vision code went through, the team came to the consensus that it was not ready. Once it becomes integrated, however, it will greatly benefit the autonomous routines, driver control, and intake and outtake [...]
By |2023-03-27T20:29:27-07:00February 6th, 2023|

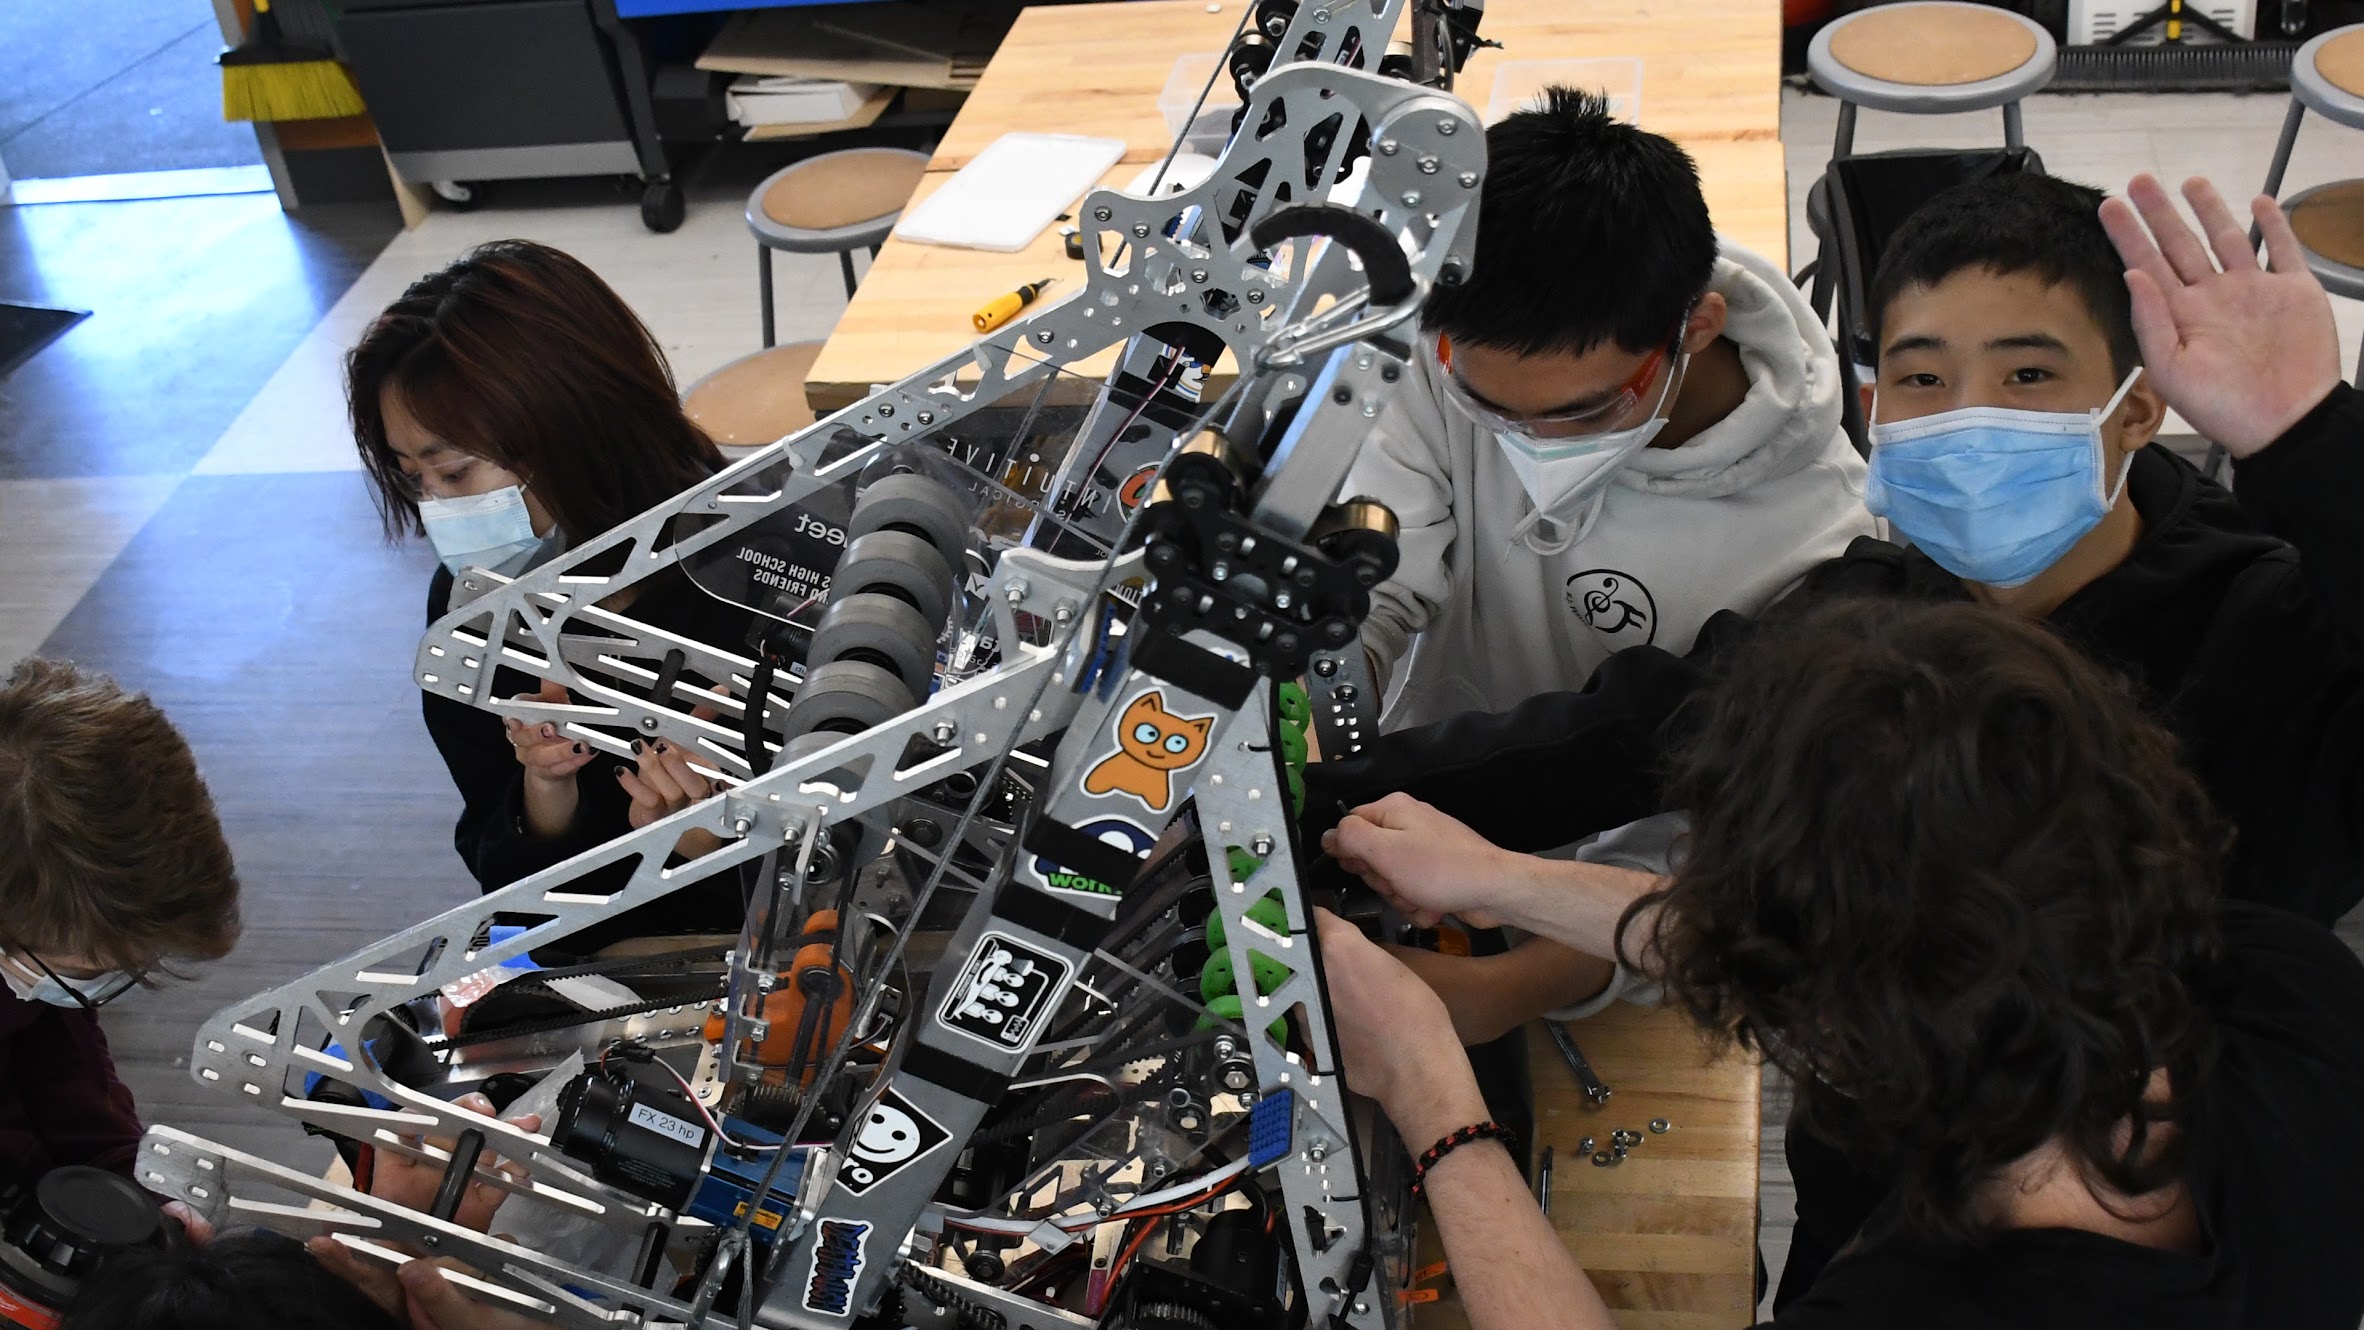
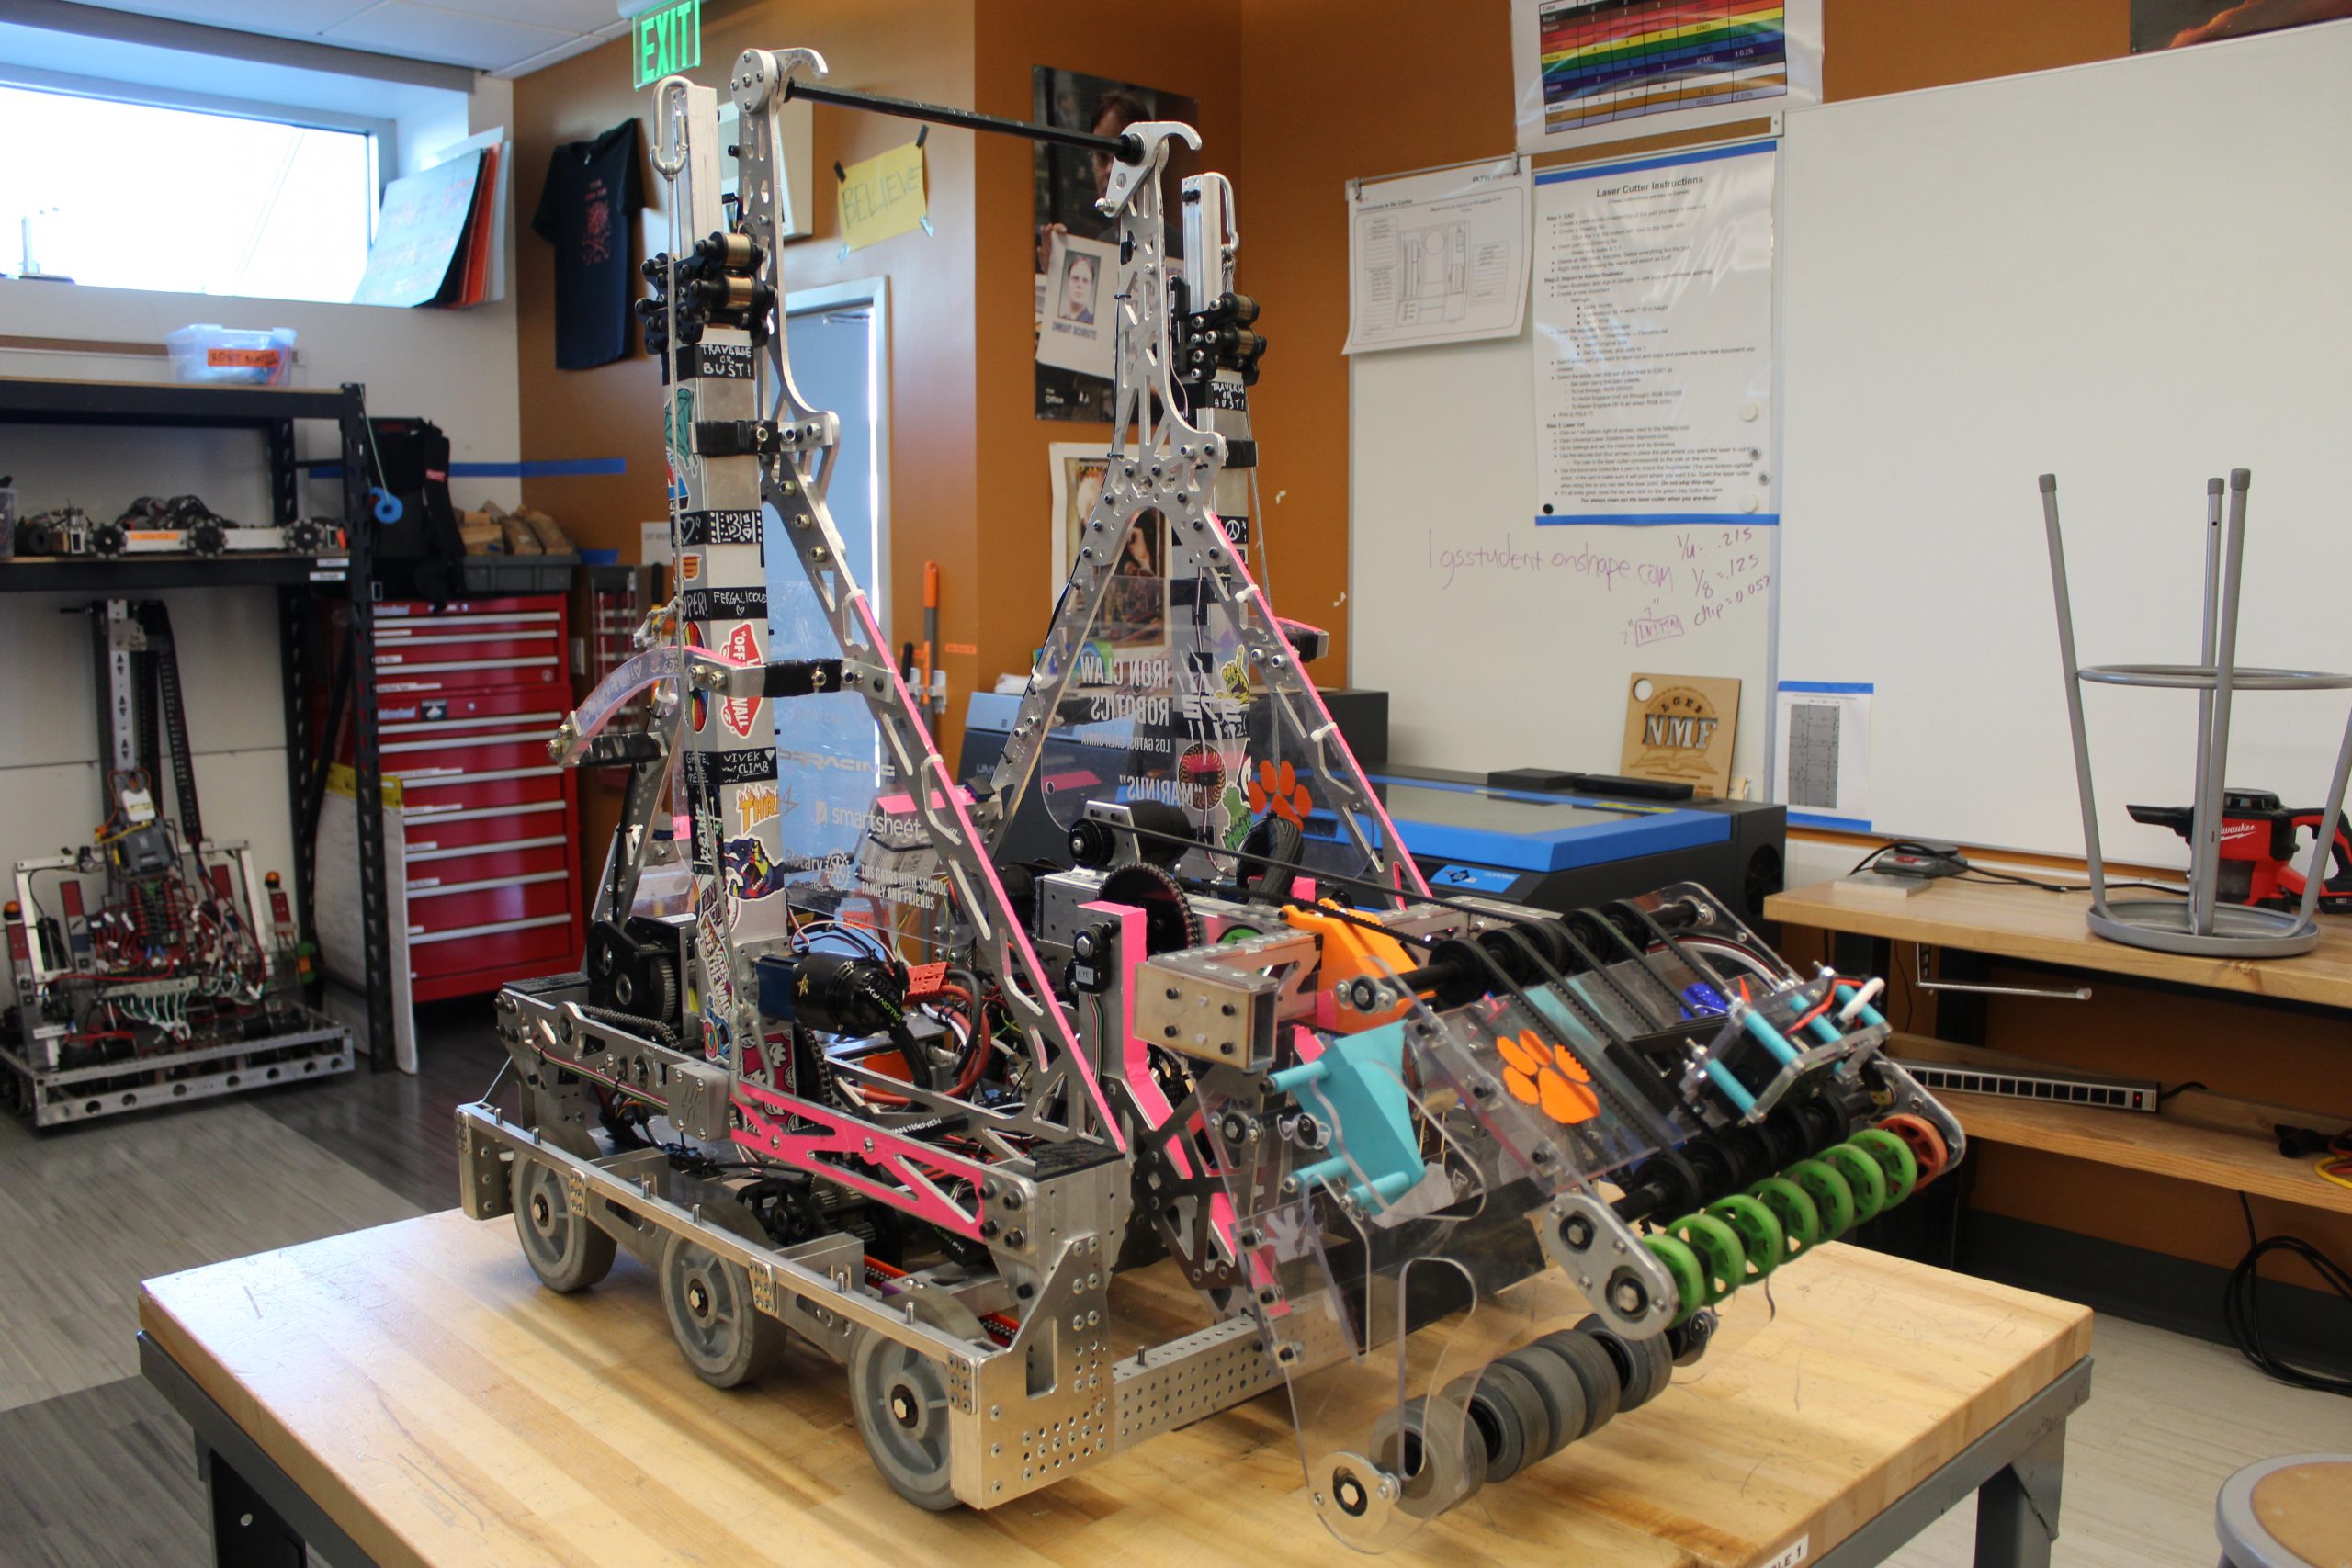
After last week’s decision to use an angled elevator with a 4 bar arm, a layered intake, and an extending bar, a lot of progress was made across all subteams in their respective areas! With detailed and precise CADs, our angled elevator team opted for continuous rigging over cascade to keep the robot’s center of mass more balanced when extending. As for rigging, they chose to use dyneema rope because it’s strong and light. They decided to use hall effect sensors for the elevator’s position detection: analog sensors for magnet distance and digital sensors or limit switches for stopping. They worked on implementing an energy chain mount, bearing blocks, and mounting it to the drivetrain. They have also been able to finish their CAD and have started making drawing files, deciding that it would be wisest to first manufacture the carriage. Our four bar arm team switched from their original design idea of a linkage 4 bar to a virtual 4 bar. They have finished CADing and are now making drawing files for machinists. Our team has also been able to add all commercial off the shelf parts and mechanisms, such as hardstops, sprockets, fasteners, and etc. So far, our layered intake is successful in intaking cones, but we are still working on cube intake. The cube is [...]

By |2023-03-27T20:30:03-07:00September 23rd, 2022|

Chezy Champs is a prestigious competition that we are proud to attend. Chezy Champs is hosted by Bellarmine high school’s robotics team, the Cheesy Poofs. Known as Team 254, they are recognized as one of the top teams worldwide and are currently the world champions of the 2022 competition season. In addition to the Cheesy Poofs, top teams from all around the world will be competing. We believe the competition will be a great learning experience for the newer students, training them and providing them competition experience so when the 2023 build season ramps up, our team’s junior members will be prepared. We are unearthing Marinus, last year’s robot, to compete again at Chezy Champs! Unfortunately, after spending the summer unused, one of the gearboxes in Marinus’ west coast drive broke. In one gear, the teeth were worn down due to incorrect spacing. Currently, we have assembled a new gearbox to replace the old one, but haven’t attached it to the robot yet. In addition to these repairs, there are some other aspects we improved: the static climb hooks and the shooter. In regards to the hooks, the rubber bands broke, so we are in the process of replacing them with a more permanent solution. As for the shooter, we are hoping to make it more accurate, [...]

By |2023-03-27T20:30:11-07:00September 18th, 2022|

Last weekend, the robotics team participated in a basic training day. The day was designed to introduce newcomers to every part of the robotics team to help them decide what part of robotics they are most interested in. Previously, this introductory training was stretched across multiple days, with a metal shop on one day, programming on the next, etc. However, the team combined all basic training into a single day this year. Most students were divided into groups of around 4-7 for each workshop. The rest of the students were the student leaders who taught each workshop. The day was separated into two categories, the first one being the metal shop and the wood shop. We were introduced to various tools that we use including circular saws, jigsaws, drills, and drivers. After learning how to safely handle these tools, we were given the opportunity to try making actual parts. We cut wood, drilled holes, deburred parts, and drove screws. While it may sound mundane, for many of the first years, it was their first time handling power tools! After many pizza slices for lunch, the second half of the day was spent in the classroom at various stations based on our additional subteams: electrical engineering, programming, and computer-aided design (CAD). There were two [...]

By |2023-03-27T20:38:23-07:00May 4th, 2022|

Excited to be back, yet well-aware of the challenges we would face due to coming back from the COVID-19 pandemic, we set humble expectations for our season and robot. We instantly recognized the importance of a consistent climb and set our initial goals as the high climb while shooting low hub. These expectations were reinforced at our first competition, the Hueneme Port Regional (HPR), and we even started shooting into the high hub as the competition went on. After our average performance, coming in 25th place after qualification matches and losing in the quarter-finals of the play-offs, we came back reinvigorated to improve on our robot.  Our unexpected success in shooting into the high hub at HPR inspired us to significantly change our robot capability goals ahead of our next regional, the Monterey Bay Regional (MBR). After analyzing areas of improvement from the Week 1 competition, we set our eyes on a traversal-climbing robot that can shoot consistently into both the high and low hub. Specifically, for the latter goal, we started integrating computer vision into our robot using Limelight, which was the first time we successfully used vision. After much tuning, we became a fairly consistent high-hub shooter. The improvements to our robot paid dividends, to say the least, [...]

By |2023-03-27T20:38:23-07:00April 11th, 2022|

We played in our final competition, Silicon Valley Regional, last weekend. Going into SVR, one of FIRST’s most competitive regional competitions, many of us were unsure how we would rank and if we would qualify for worlds. But through our persistence and hard work, we performed much better than we expected. The SVR grind began two weeks earlier, right after we competed in the Monterey Bay Regional. Our performance was extraordinary compared to previous years and we ranked 4th at the end of the qualification matches. We only needed some minor changes to our climb before we focused on improving our cargo mechanism and decreasing cycle times. The weekend before SVR began with a rapid round of prototyping to modify the geometry of the claw. The side plates that held on the shooter wheels would hit away cargo and made it difficult to reliably intake cargo, even with a ball chasing program. As a result, we modified our side plates to include slight cutouts that increased our acquisition zone significantly. In addition, our limelight, which was mounted directly on the claw, got damaged at MBR so we refashioned a new mount that protected it from impact. .        Once the cargo fixes were done, the robot was handed off to the programmers so they could finish [...]

By |2023-03-27T20:38:23-07:00March 28th, 2022|

Last weekend, our team traveled to Monterey Bay to compete in the Monterey Bay Regional. Unlike at Hueneme Port Regional, almost our entire team went to this competition. On the first day, the pit crew and drive team drove early in the morning to Monterey and set up the pits. Inspection and robot weighing went fairly smoothly, except for a camera module that was causing the current to not properly ground. In between the inspection, we finished attaching our climb mechanism to the robot and performed some system checks with the programmers to confirm that the robot was in working order. After this, we rushed to the game field to calibrate our robot for the field. Field calibration, something our team never had the chance to do in the past, was particularly useful for optimizing the consistency of our vision alignment and planning a precise autonomous sequence. Afterwards, our drive coach and strategy lead toured the other pits at the competition to learn more about our competitors and their robots. They compiled a comprehensive list of teams’ match strategies and robot capabilities. When the practice matches began, our robot did decently well, consistently maneuvering a two-cargo autonomous routine, shooting several upper hub cargo in teleop, and climbing to the traversal bar. However, we were not able to shoot [...]

By |2023-03-27T20:38:23-07:00March 9th, 2022|

Last weekend, we traveled down to Port Hueneme to compete in our first regional competition. The week leading up to the competition was filled with challenges, but after finishing up our cargo arm and putting some finishing touches on our climbing mechanism, we packed up for the 5 hour drive. We still had numerous challenges to overcome in the week leading up to the competition. Due to parts being backordered, our cargo arm was coming together slower than expected. The final days before competition were filled with programming and testing of intake, limelight alignment, and shooting. At the end of the week, we had a decent autonomous routine that shot one ball into the low hub and taxied out of the tarmac. Our arm was getting tuned for low hub shooting and the drive team was able to get in some practice time. The climb was also recovering from some roadblocks. After testing our climbing mechanism, we found that the end caps of the thrifty bot elevators were shearing along the 3D printed layers. Our robot dropped like a rock in our first climb, but we redesigned and increased the strength of our endcaps, elevators, and hooks. Going into the competition, we had a solid mid climb and planned to test a high climb on the practice field. [...]

By |2023-03-27T20:38:23-07:00February 20th, 2022|

Now that there’s no more stop build day, we don’t have to worry about bagging and tagging or bot anymore, but we’re nonetheless rounding the corner towards testing and practice! There are just about two weeks until our first competition at HPR. The drivetrain is confidently 100% done at this point, with the new wheels and shafts installed. Now our main priority is attaching our other subsystems and getting in a little driver practice as time permits. We’ve made great progress on our climb subsystem over the course of this week. With the exception of the hooks at the top of our climb, the telescope and superstructure have been fully machined and assembled. Programmers have gotten some time to test out their rotation code, and with very little backlash, our climb arm can rotate with PID control to within just a couple degrees! We encountered some stability issues (aka severe wobbling), but nothing an additional support hex shaft can’t handle! With just a couple more days, the entire subsystem is ready to be handed off to the programmers for testing. Fingers crossed for no more mechanical issues or redesigns! The whole CAD for our cargo subsystem has been finalized and approved this week. The structural components have largely already been assembled, and we’re starting [...]

By |2023-03-27T20:38:23-07:00December 16th, 2021|

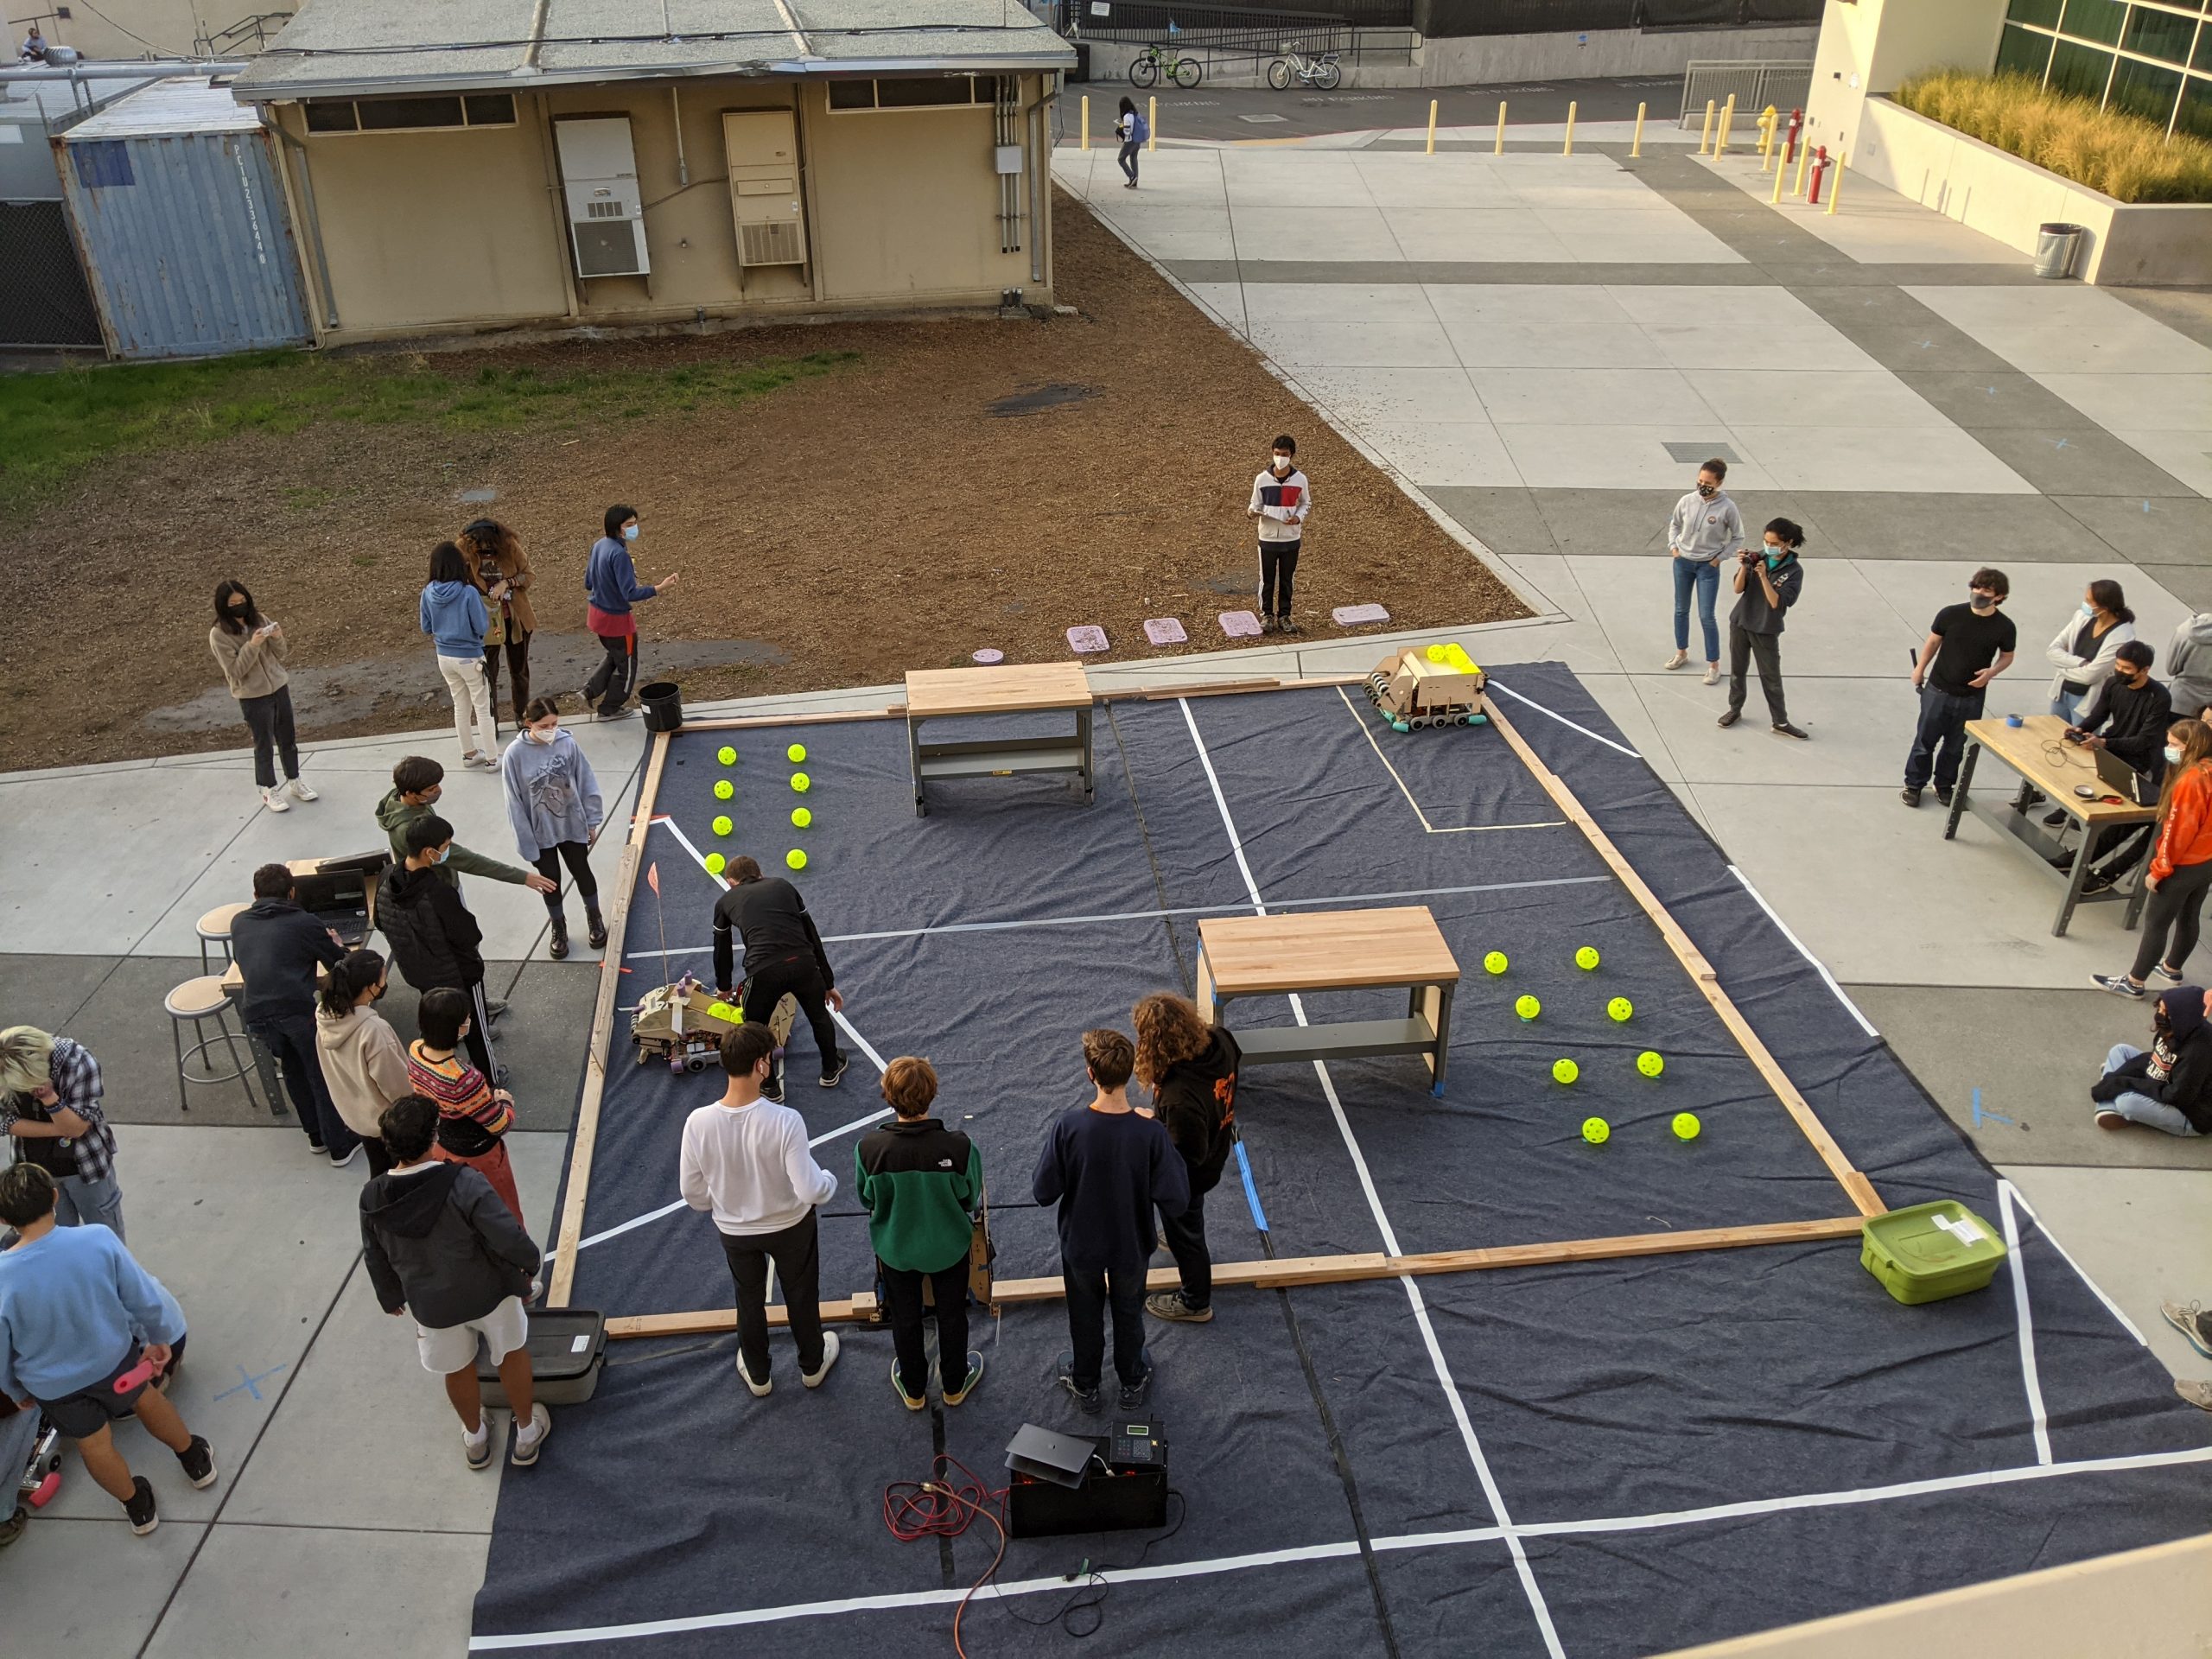
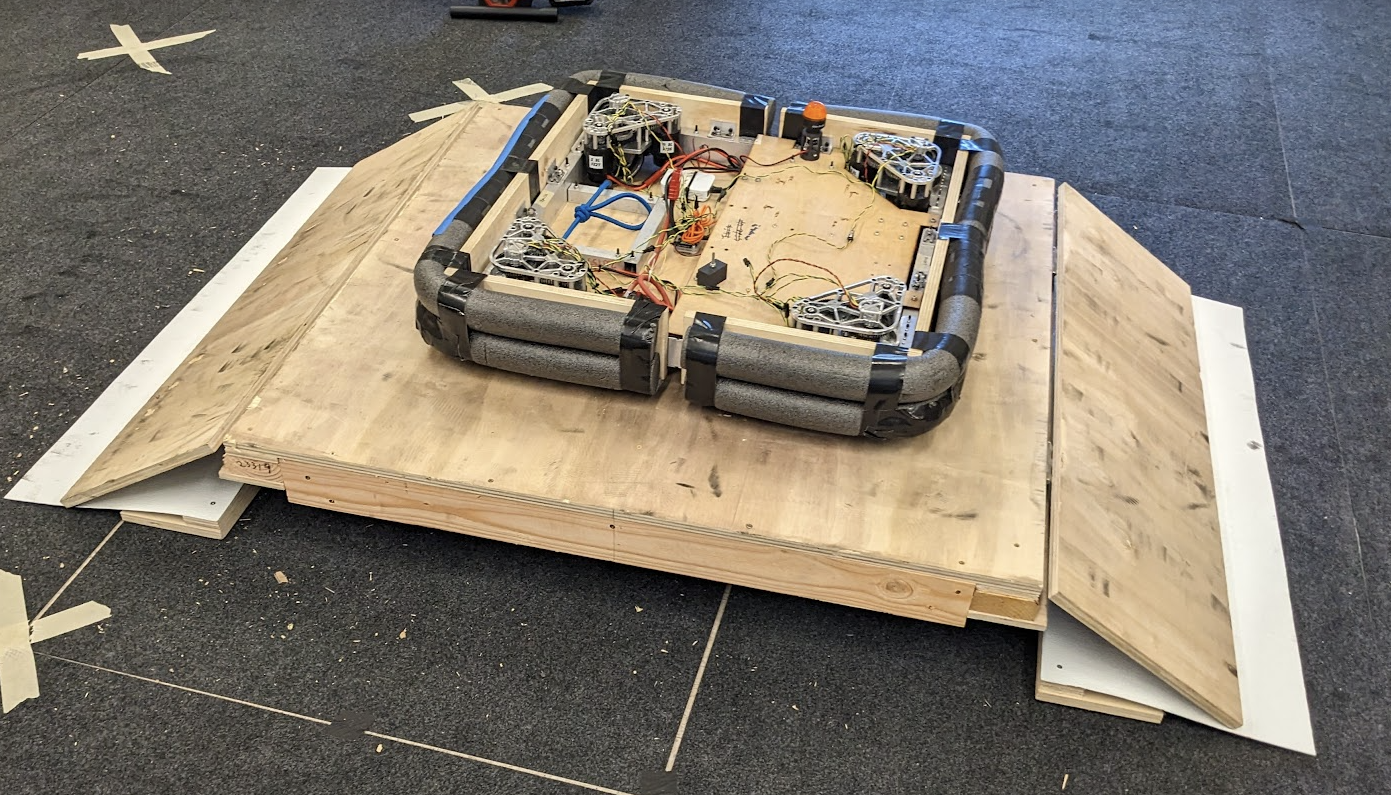
Class Competition For the class competition, we split the class into four different teams. Each team was given a rules manual and a few weeks to design a robot that fit said parameters, which is a direct representation of our build season process. The purpose of the class competition was to prepare our team for the upcoming competition season. Students took part in the designing, building, and refining process for each of their team's robots, gaining vital technical and teamwork skills.  The objective of the competition was to score the most points at the end of each round, which included two teams completing an autonomous and remote control operated period. During the autonomous period, robots scored points for crossing the midline and for depositing wiffle balls into their team's bank. During the remote controlled period, drivers employed various creative offensive and defensive strategies to either deposit balls into their scoring zones or prevent other teams from scoring. As the teams progressed through their builds, many structural, programming, or knowledge based challenges were encountered. The best part about this competition was seeing how each team persevered to overcome struggles and to build a functioning robot. After the class competition, our class collectively became better at problem solving and more prepared for build season. This [...]

Go to Top